Xiamen Xingruijia Import and Export Co., Ltd. has been specializing in the sales of industrial control equipment spare parts for 20 years. For more ABB models, please refer to the product list . If you need other brands or models, please contact us. We have a variety of brands and models in stock, and we can purchase difficult to order models for you. We look forward to your inquiry!!!
First hand source//affordable price//Spot inventory!
•Shipping Port: Xiamen
•Manager: Rhonda
•E-mail: sales7@saulplc.com
•Tel/WhatsApp/Wechat: + 86-15359273796
•Ship to you via Fedex/DHL/TNT/UPS/EMS
•Package: Original packing with cartons
ABB 3HAC022544-008
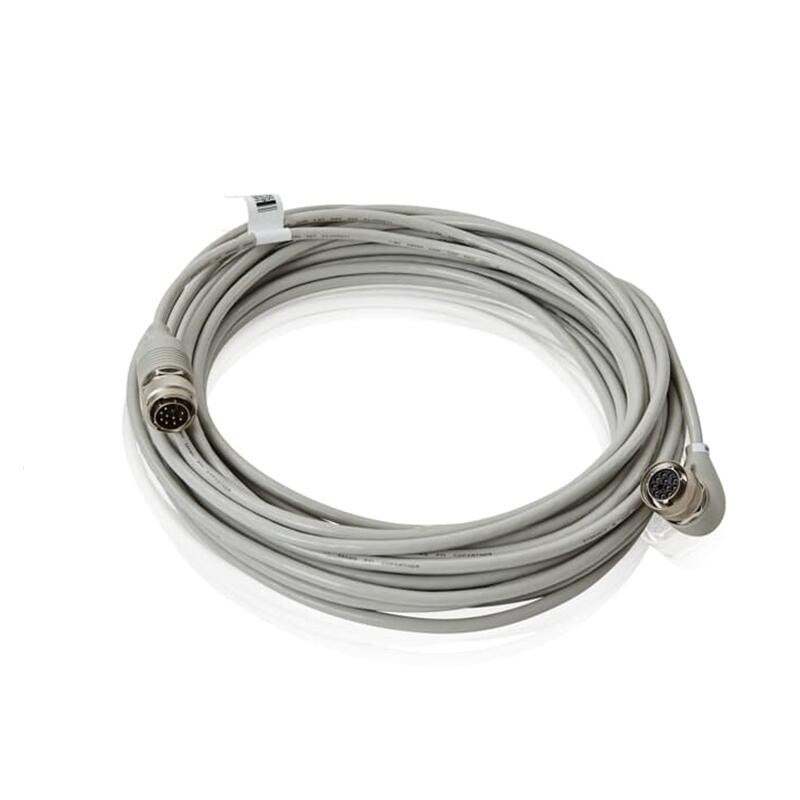
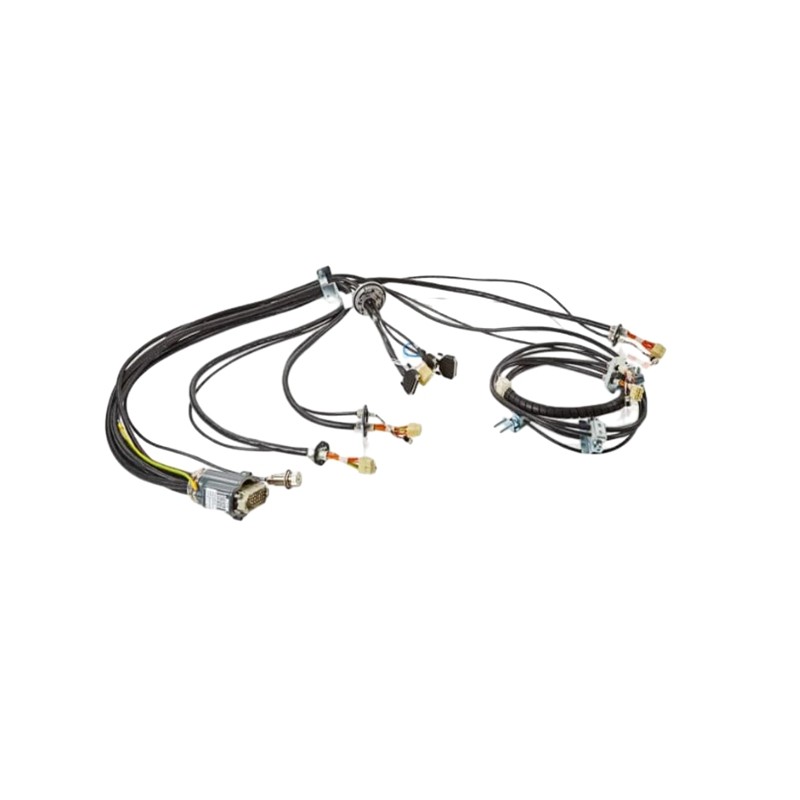
The ABB 3HAC022544-008 is an ABB Robotics manipulator cable harness assembly designed for ABB articulated robot systems. It is mainly used for the electrical connection and signal transmission of the robot manipulator axes 1–6, providing reliable wiring between the robot arm components and the control system.
This spare part belongs to ABB robot maintenance components and is commonly associated with the ABB IRB 660 robot family. It is used as a replacement cable harness during robot repair, refurbishment, or preventive maintenance operations.
Product Parameters
| Parameter |
Description |
| Manufacturer |
ABB |
| Product Number |
3HAC022544-008 |
| Product Type |
Robot Manipulator Cable Harness |
| ABB Description |
Cable harness, man ax.1-6 |
| Application |
ABB Industrial Robots |
| Compatible Robot Family |
ABB IRB 660 (verify exact configuration before replacement) |
| Axis Coverage |
Axis 1–6 |
| Component Function |
Power, feedback and signal wiring connection |
| Installation Location |
Robot manipulator arm |
| Weight |
Approx. 7 kg (reference value) |
| Product Category |
Robotics Spare Parts |
Core Function
The ABB 3HAC022544-008 cable harness performs several important functions in robot operation:
- Provides electrical routing between robot joints and the robot controller system.
- Transfers motor power, encoder feedback, brake signals and control-related wiring.
- Maintains stable communication and power supply during multi-axis robot movement.
- Supports continuous bending and dynamic motion conditions inside the robot arm structure.
A properly functioning harness is essential for maintaining robot positioning accuracy, motion reliability and operational safety.
Design Features
High Flexibility Robot Cable Structure
Designed for articulated robot applications, the harness is manufactured to withstand repeated bending, twisting and continuous movement during robot operation.
Integrated Axis 1–6 Wiring
The assembly combines the wiring required for the robot's six-axis manipulator structure, reducing installation complexity compared with replacing individual cables.
ABB Original Spare-Part Design
The cable routing, connector arrangement and mechanical installation points are matched to ABB robot maintenance requirements. Replacement should always be confirmed using the complete part number and robot configuration.
Hardware Composition
The ABB 3HAC022544-008 mainly consists of:
- Multi-core industrial robot cable assembly
- Axis motor power cables
- Encoder and feedback signal lines
- Brake/control wiring
- Robot-side connectors
- Protective cable sections and routing elements
The harness is installed as part of the robot manipulator cable system and works together with mechanical cable guides and protective covers.
Typical Applications
The ABB 3HAC022544-008 is typically used in:
- Automotive manufacturing robot lines
- Welding and assembly automation
- Material handling systems
- Heavy-duty industrial robot cells
- Robot refurbishment and overhaul projects
- Spare-part inventory for ABB robot maintenance teams
Typical maintenance scenarios include:
- Cable wear replacement
- Robot collision repair
- Preventive maintenance
- Restoration of discontinued robot systems
Maintenance Considerations
When replacing the ABB 3HAC022544-008 cable harness:
- Confirm the robot model and complete ABB spare-part number before installation.
- Record original cable routing and connector positions.
- Check cable bending radius and mechanical clearance.
- Inspect connectors for oxidation, looseness or damage.
- Perform continuity and insulation checks after installation.
- Test robot movement at reduced speed before returning to production.
Incorrect cable routing may cause abnormal robot movement, signal errors or premature cable damage.
Overall Evaluation
The ABB 3HAC022544-008 is a critical robot maintenance component for ABB IRB 660-class robotic systems. As a dedicated Axis 1–6 manipulator cable harness, it plays an important role in ensuring stable electrical transmission and reliable robot motion performance.


 Sweden